Pick Strategy
The Pick Strategy page is used to define how RoboPick selects a pick pose from the detected objects. User can specify the object's pick location, the gripper TCP frame, create collision zones in order to find the best pick pose.
Gripper TCP frame and collision model
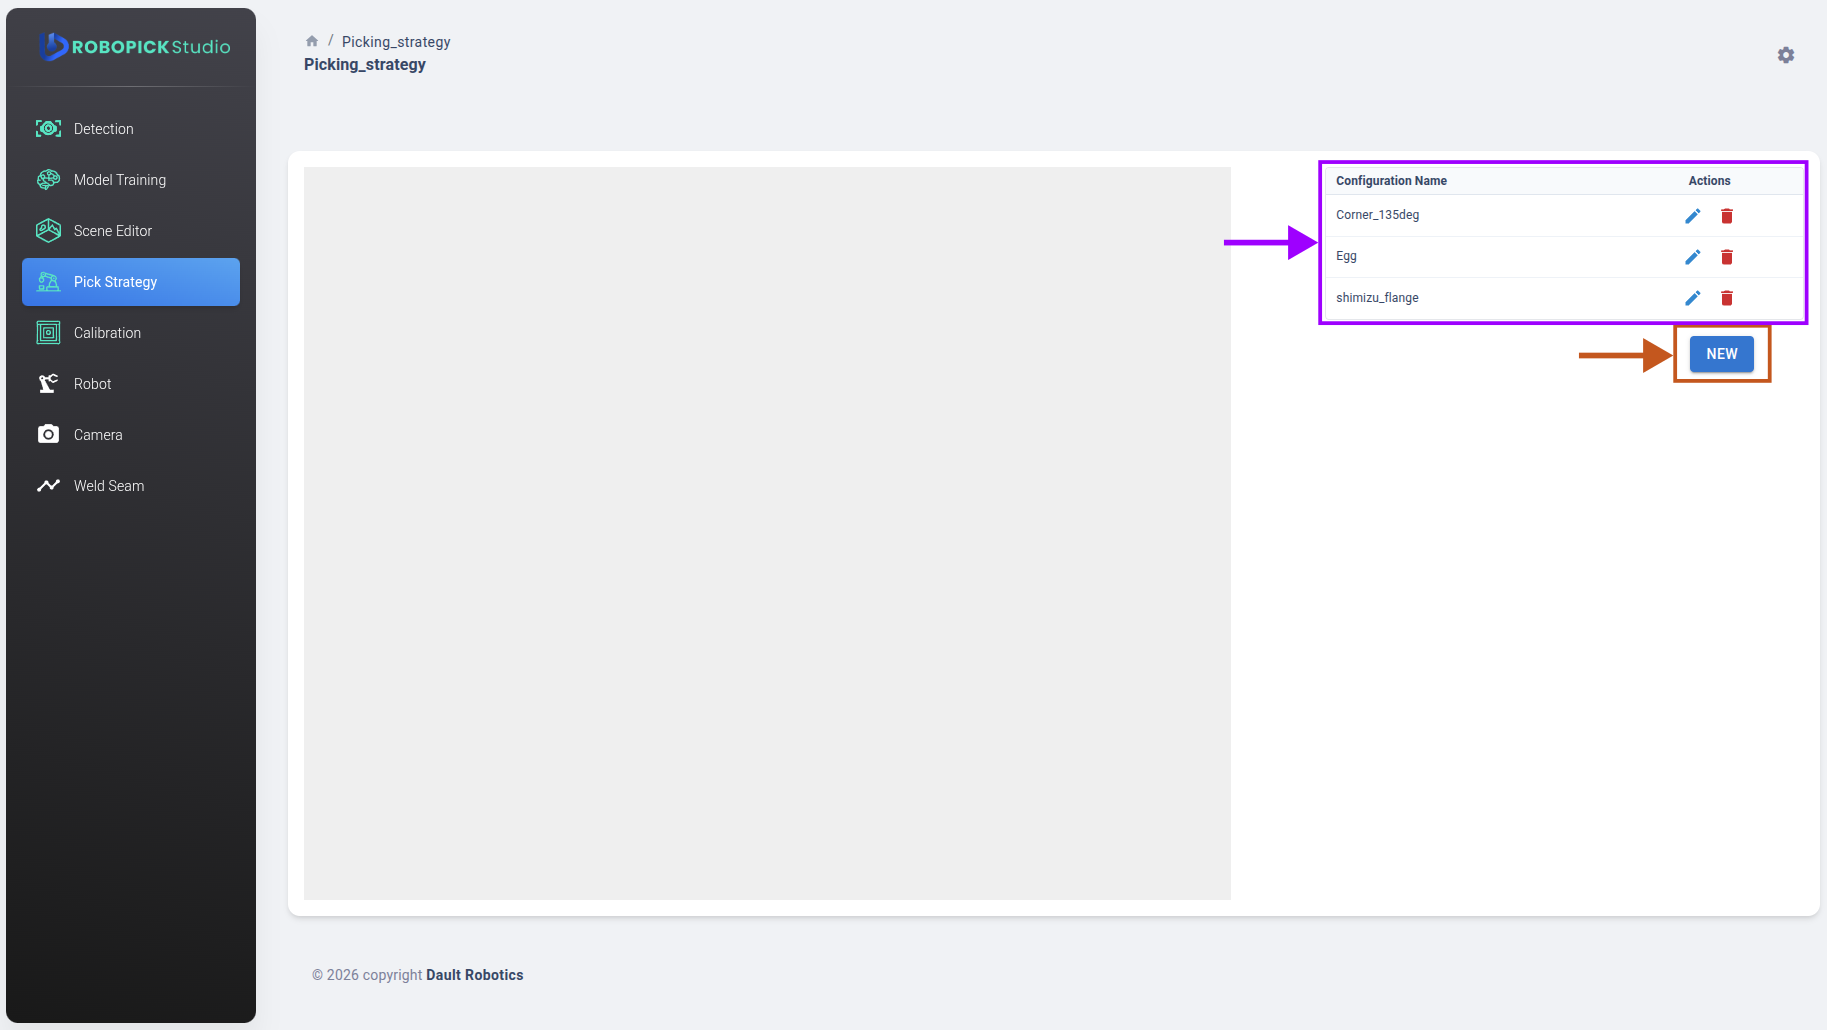
- Go to localhost:3000/picking_strategy. Create a new pick strategy by clicking the "NEW" button.
- The first step is to upload the tool CAD model. Acceptable formats are STL, PLY and OBJ. Click Browse CAD and select the file. After selecting, the tool mesh will be shown on the left viewer. In this example, we have a parallel gripper that we will use a two fingered parallel gripper.
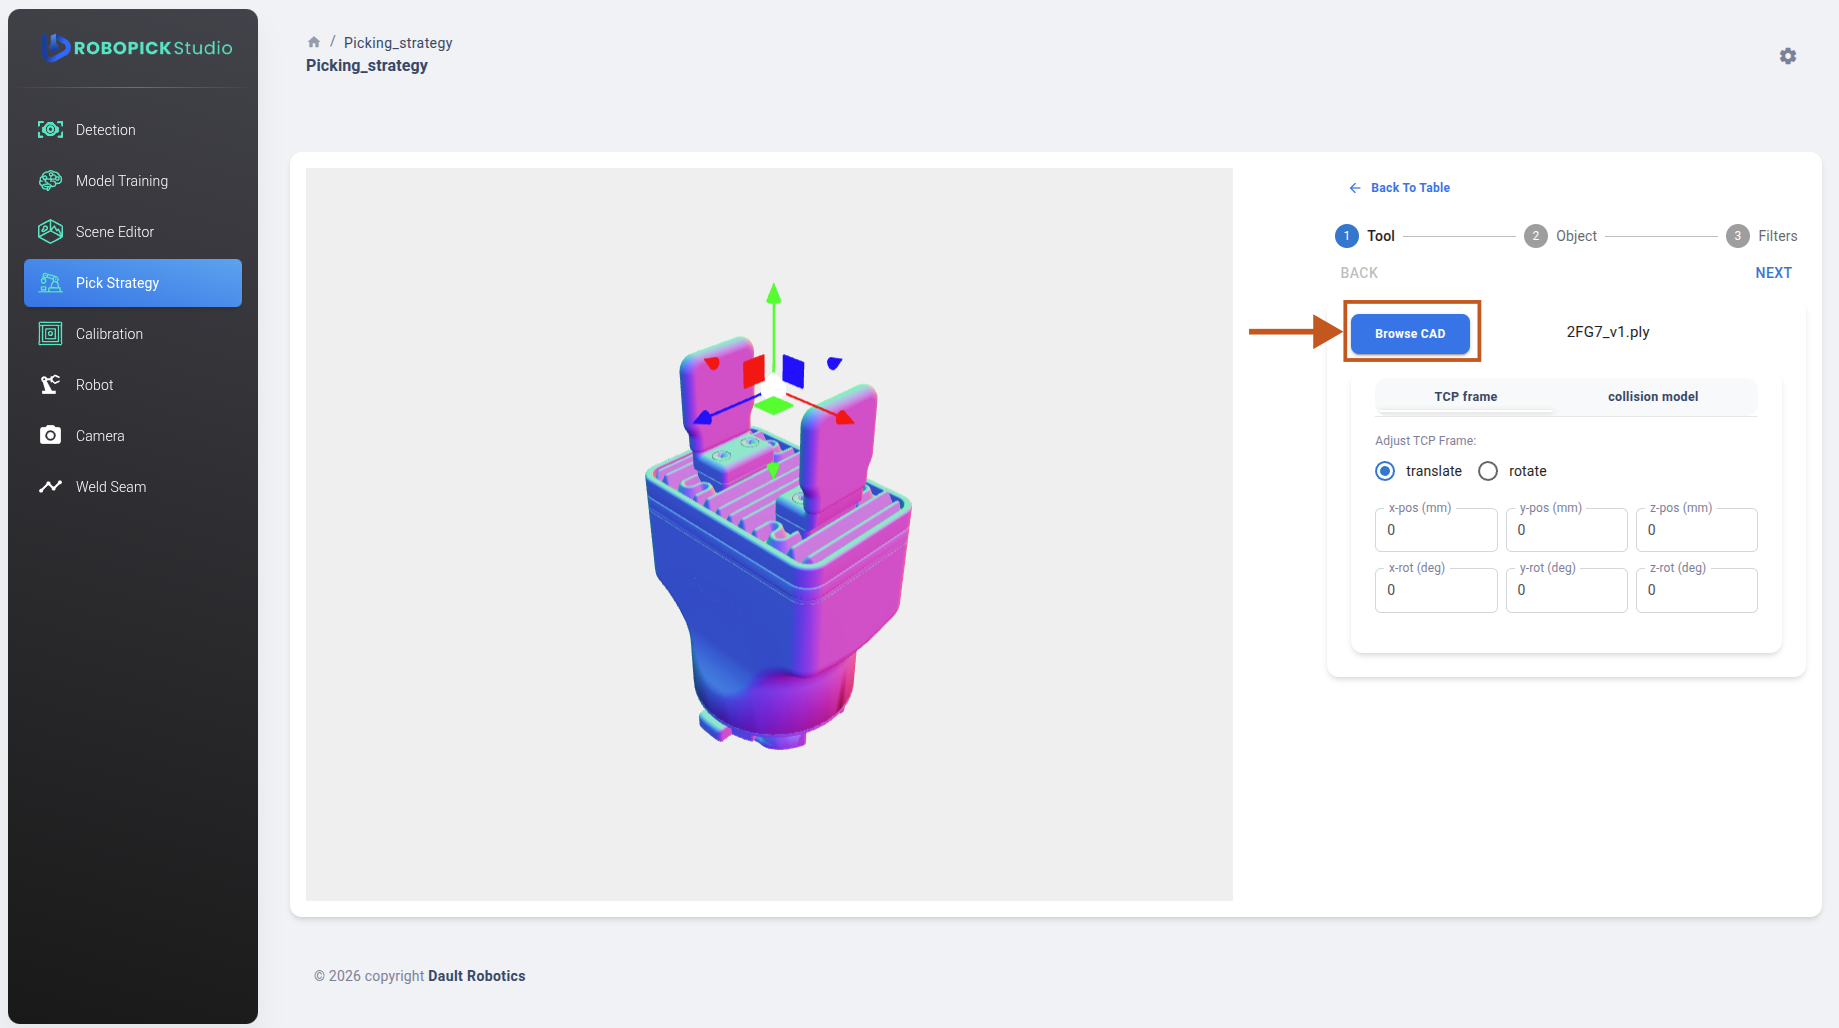
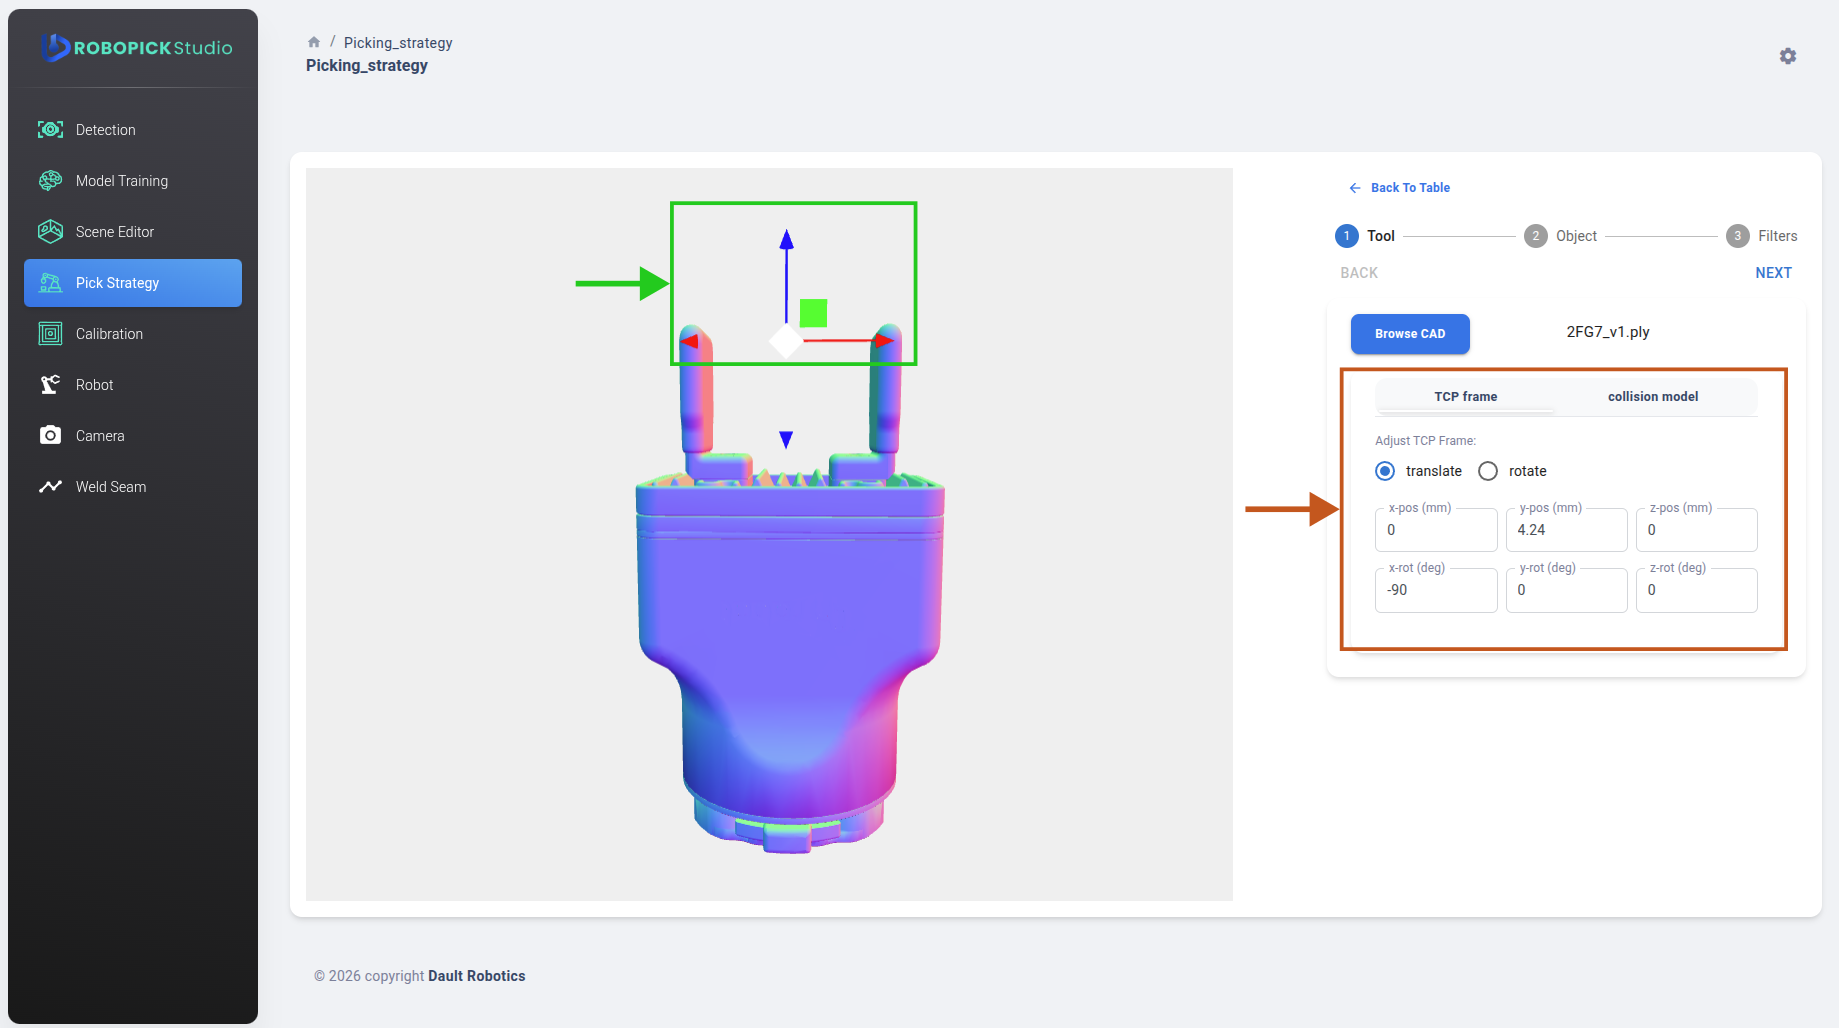
- The next step is to adjust the TCP position of the tool. This will be the frame that will be moved towards the object's pick frame. You can move and rotate the TCP frame by dragging and dropping the axis widget indicated in Figure 3, or you can also input the precise TCP position and rotation on the number fields on the right. In this example, we position the TCP in between the gripper's fingers. Furthermore, we also rotate the TCP -90 degrees around x axis so that the TCP's positive z-axis is pointing towards the picking direction.
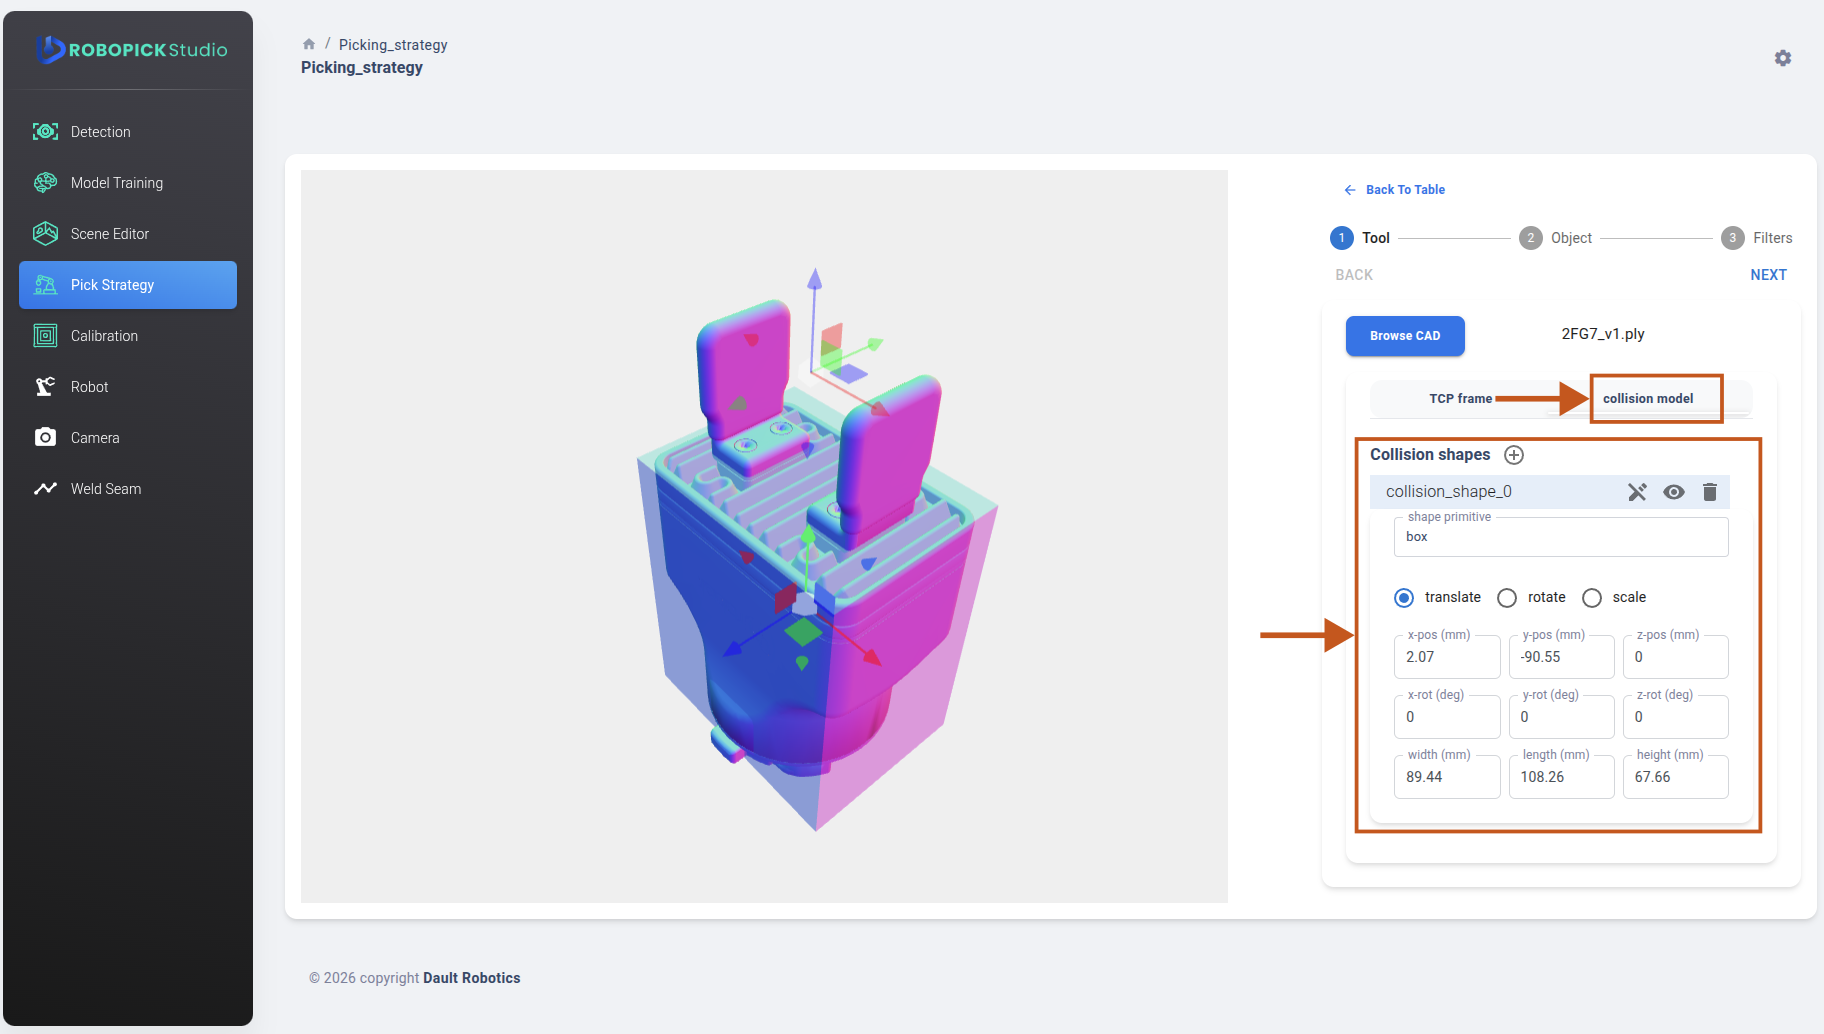
- In order to avoid the gripper colliding with the objects and surrounding when picking, we need to add collision model to the gripper. Collision model is a specified by means of adding collision zones. These zones can be represented as three shapes: box, sphere, and ellipsoid. A gripper can have several collision zones. To add them, go to collision model tab, and click the + sign to add a collision shape. Choose the shape primitive and adjust its position, rotation, and dimension. You can also use the eye and trash icon to show/hide and delete the shape. In this example, we can approximate the gripper's body with a box shape primitive. We adjust the box's position and dimension so that it fits the gripper's body. We add a few mm margins on the dimension to compensate for model inaccuracy and sensor noise.
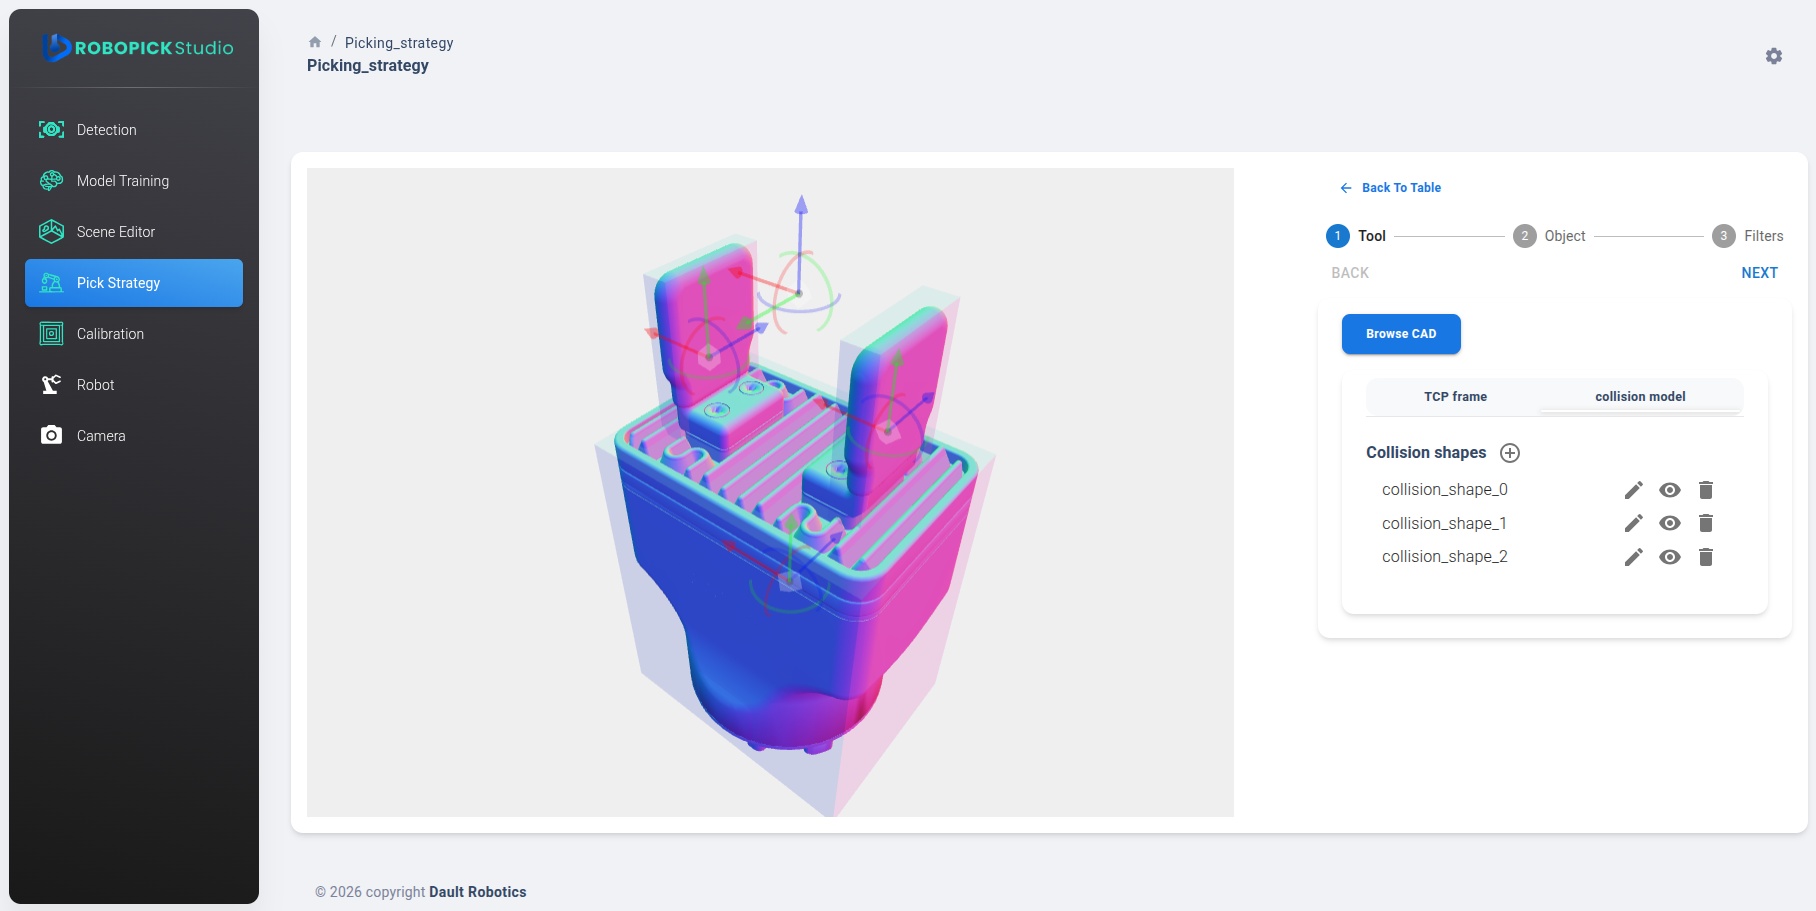
- Now that we have a collision zone for the gripper's body, we can add two more collision zones for the fingers. Then, we click Next.
Object and grasp frames
In this stage, we can load the object that we want to pick. Select the stored object model from the dropdown menu, and click Load. This left viewer will show the object's mesh.
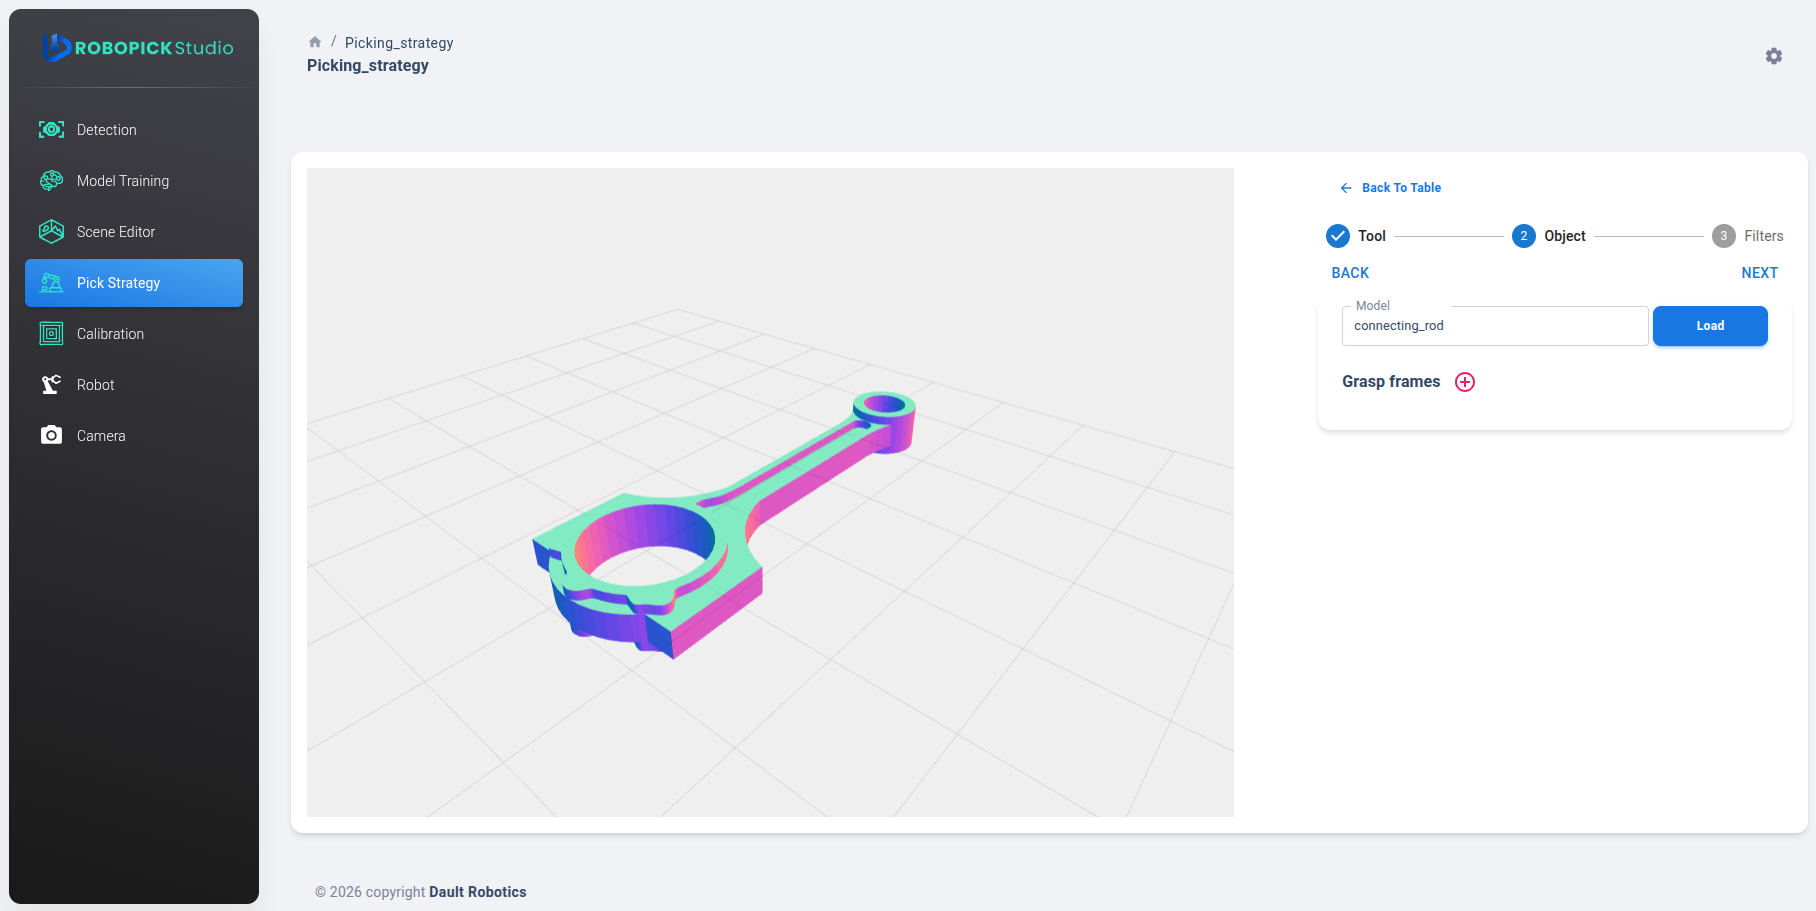
Afterwards, we can add a grasp frame, which is how we specify the gripper should be positioned relative to the object. The control widget can be used to translate and rotate a grasp frame. Here, we position the grasp frame to pick the object, a connecting rod, by its beam/shaft.
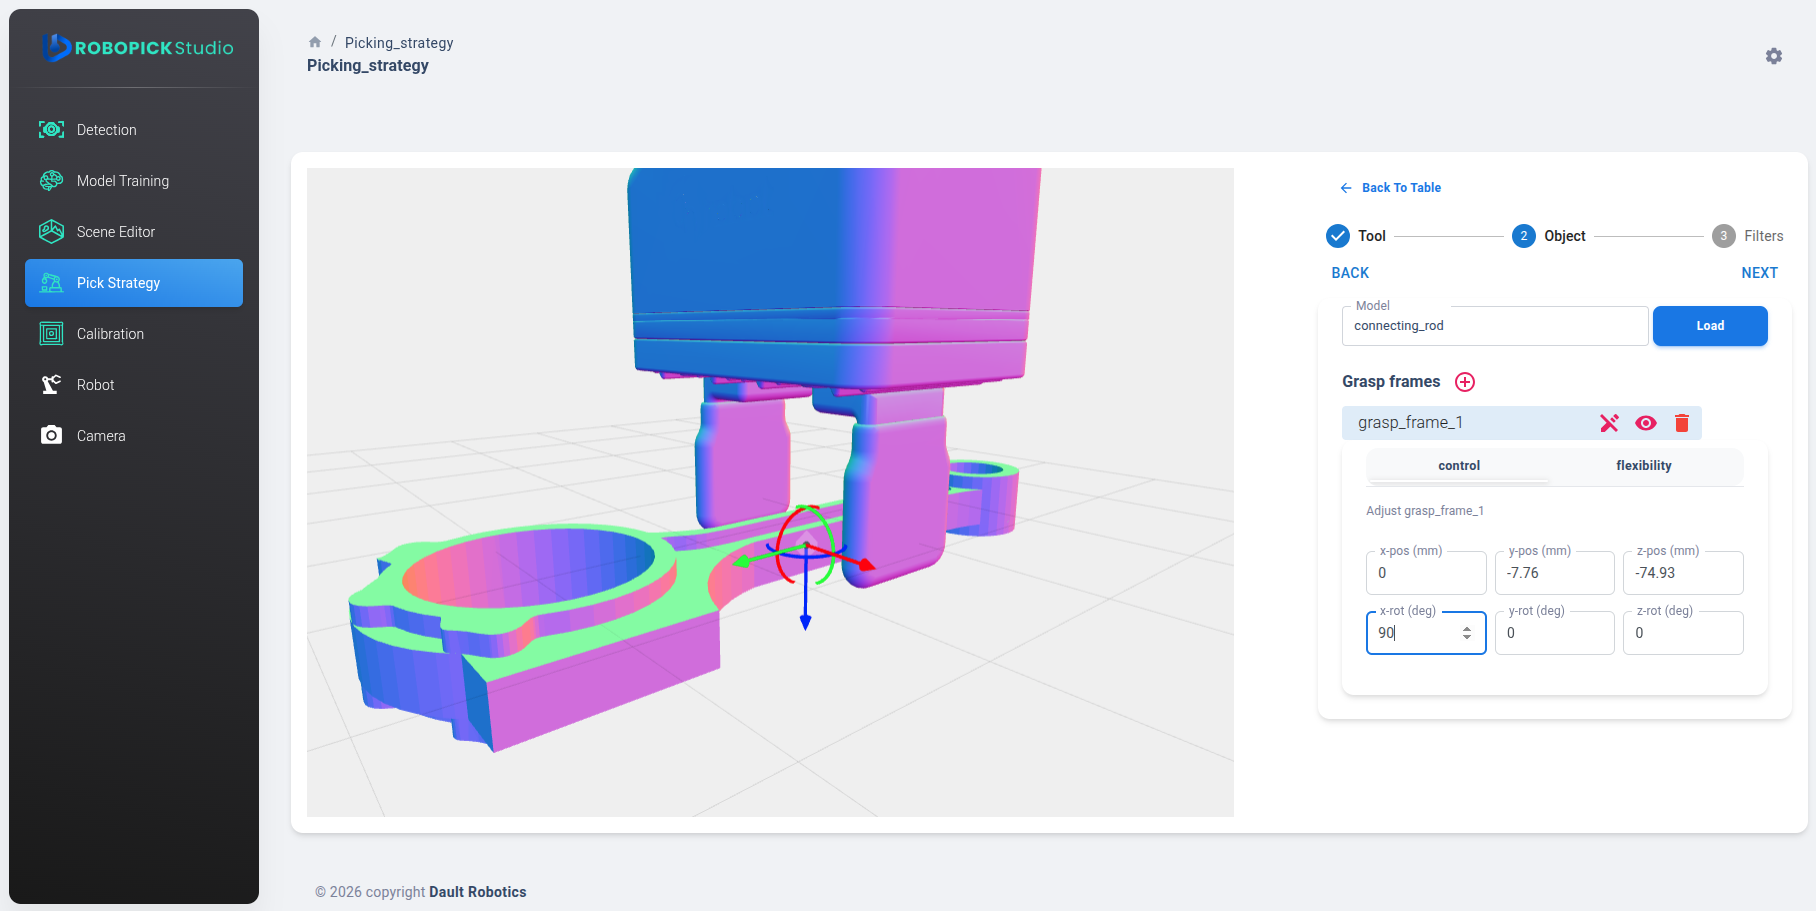
Since an object can possibly be picked from different positions, multiple grasp frames can be added. In this example, we add another grasp frame to pick the connecting rod by its hole. Once we are done, we can proceed by clicking Next.